Applanix | POS LVX+125 GNSS-Inertial System
GNSS-inertial system for mobile mapping with an onboard and an external IMU: 0.03° roll/pitch and 0.09° heading with CenterPoint RTX corrections.
GNSS-inertial system for mobile mapping with an onboard and an external IMU: 0.03° roll/pitch and 0.09° heading with CenterPoint RTX corrections.
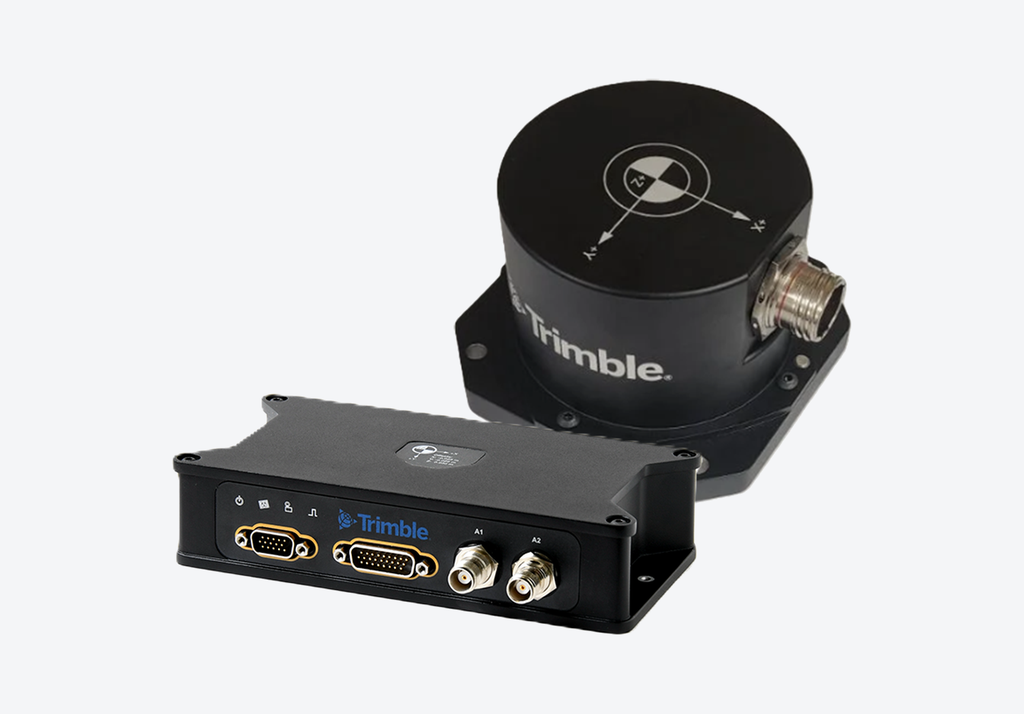
GNSS-inertial positioning for reliable, efficient and high-accuracy mapping, powered by CenterPoint RTX
The Applanix POS LVX+125 is engineered to improve the efficiency and precision of mapping operations in both real-time and post-processed workflows. It suits projects built around LiDAR sensors or cameras, as well as fleet management and automotive applications. Trimble CenterPoint RTX corrections deliver high real-time positioning without an RTK network, which removes the base-station overhead from a survey.
The system is a single rugged enclosure housing a high-precision dual GNSS receiver, an embedded inertial sensor unit (IMU Type 79), an external inertial sensor unit (IMU Type 97) and onboard data logging with full interface support. Odometry (DMI) input is fully supported. It ships with Applanix POSPac Complete, factory enabled, including Applanix IN-Fusion+ with PP-RTX post-processing.
Typical performance; actual results depend on satellite configuration, atmospheric conditions and other environmental effects. Specifications subject to change without notice. Source: Applanix POS LVX+125 datasheet PN 022520-136A (04/26).