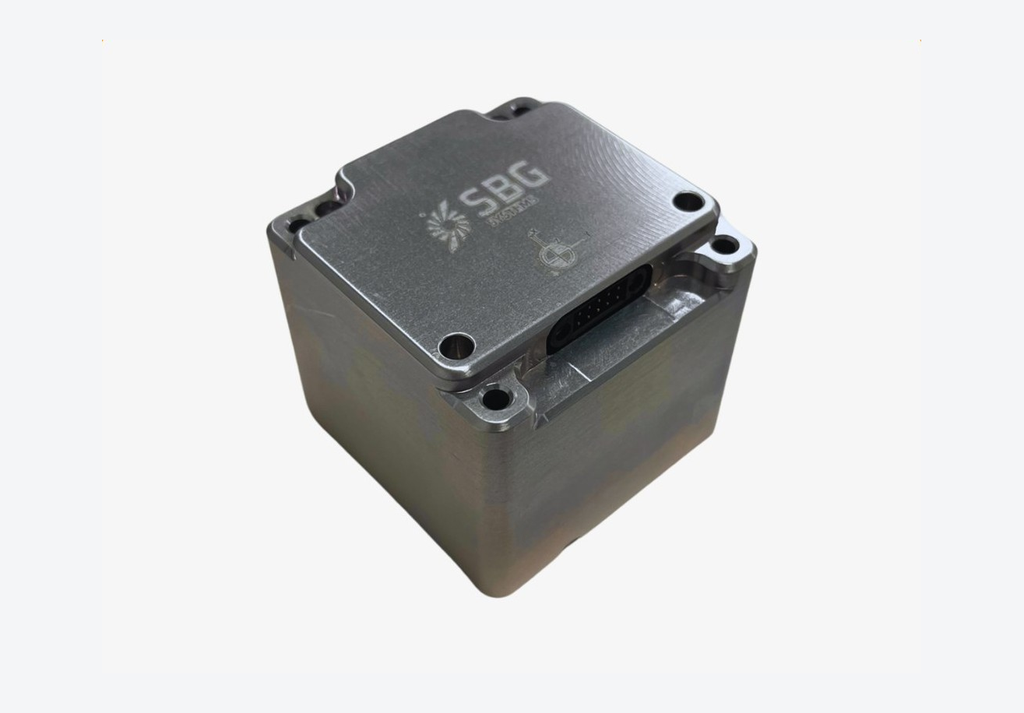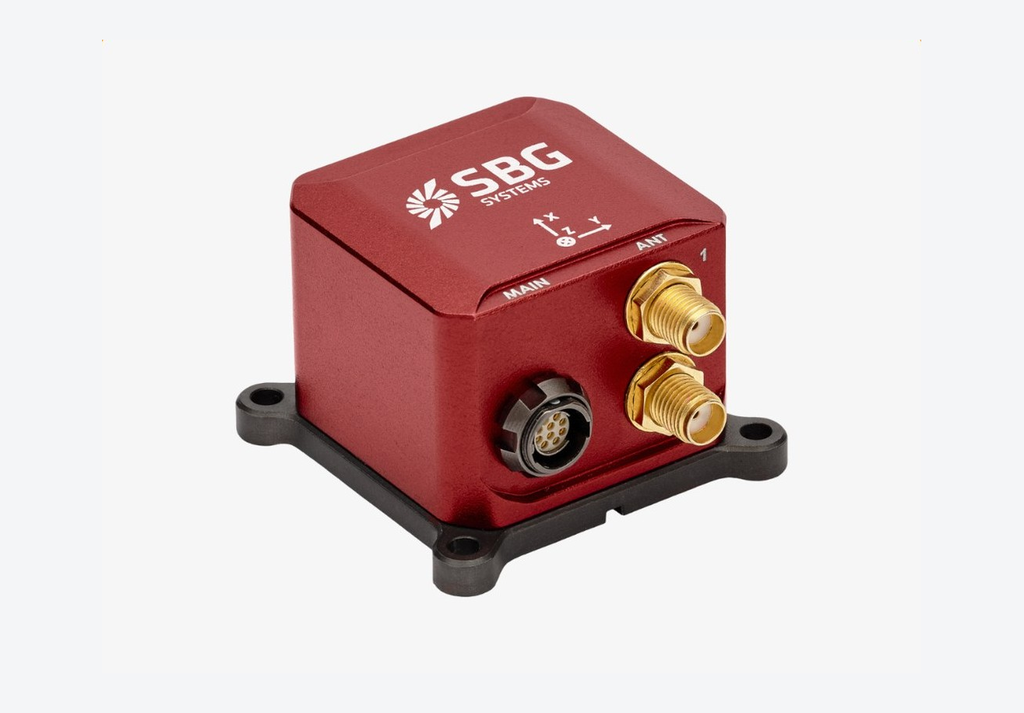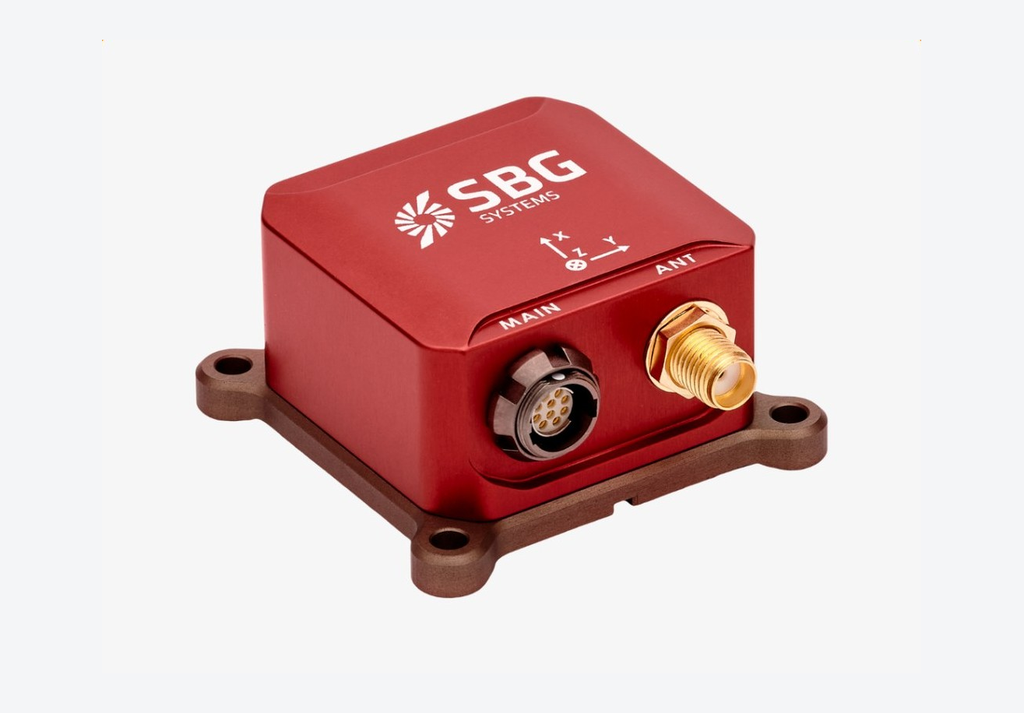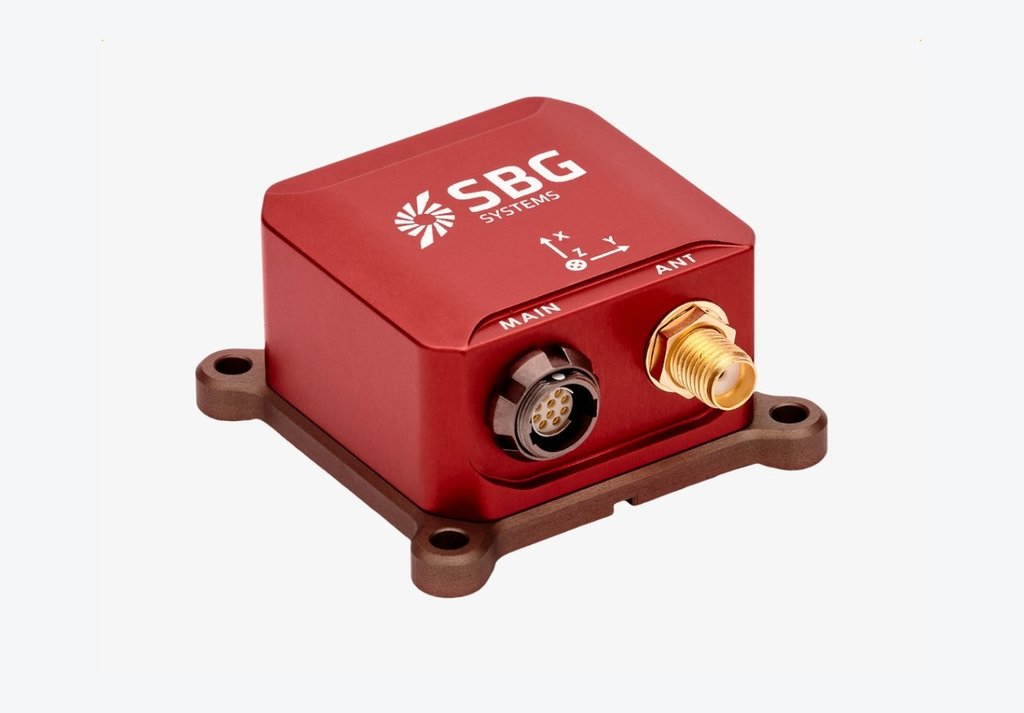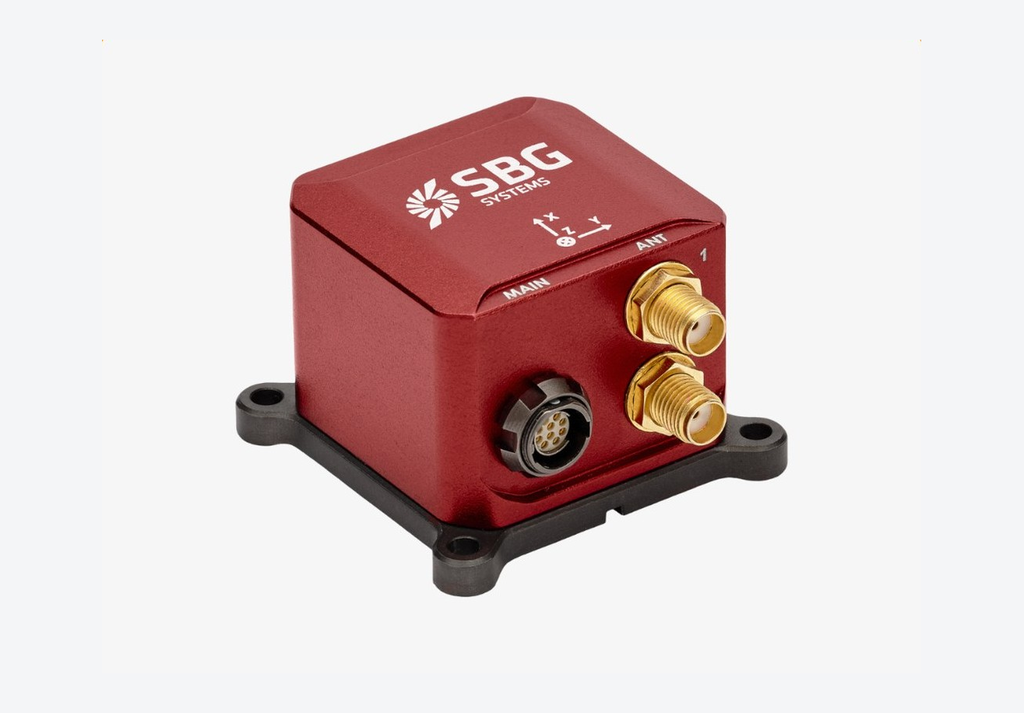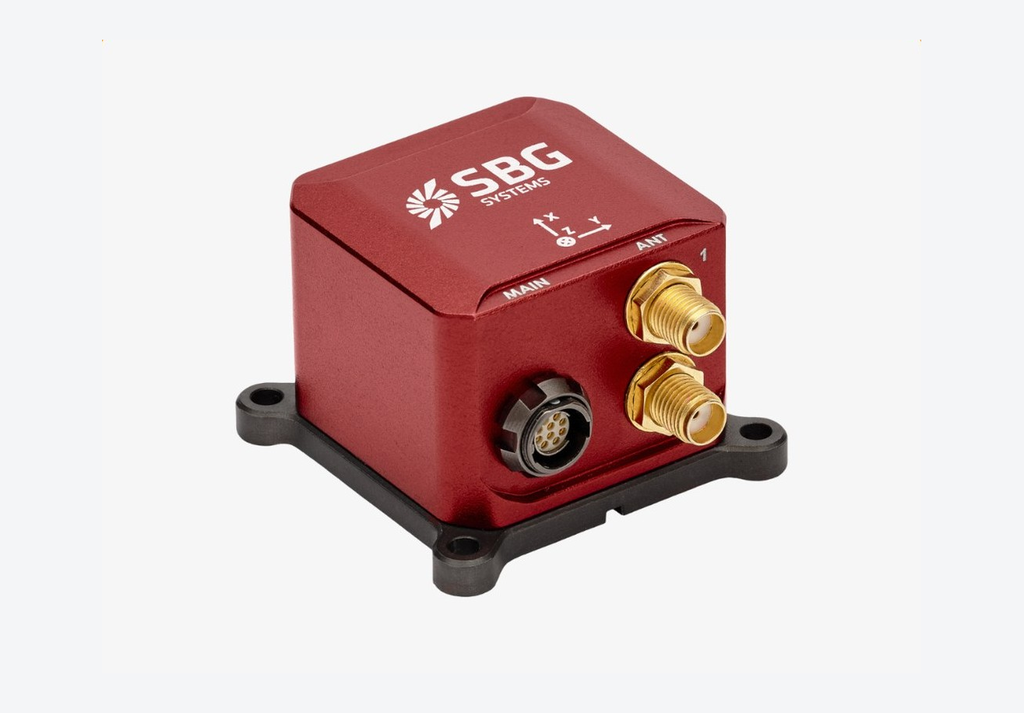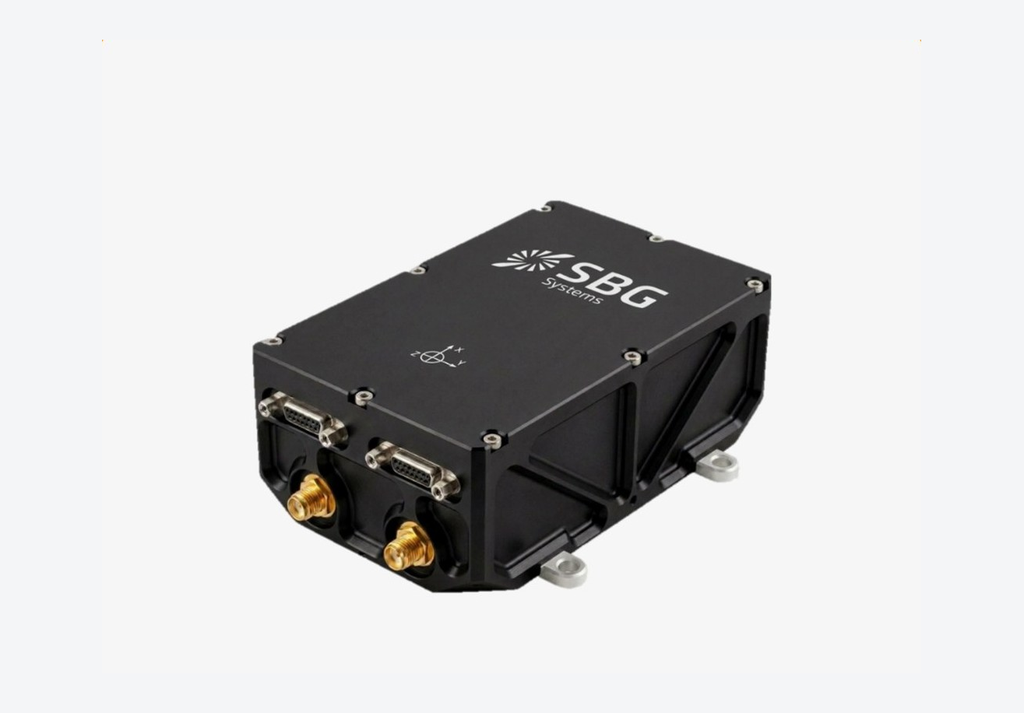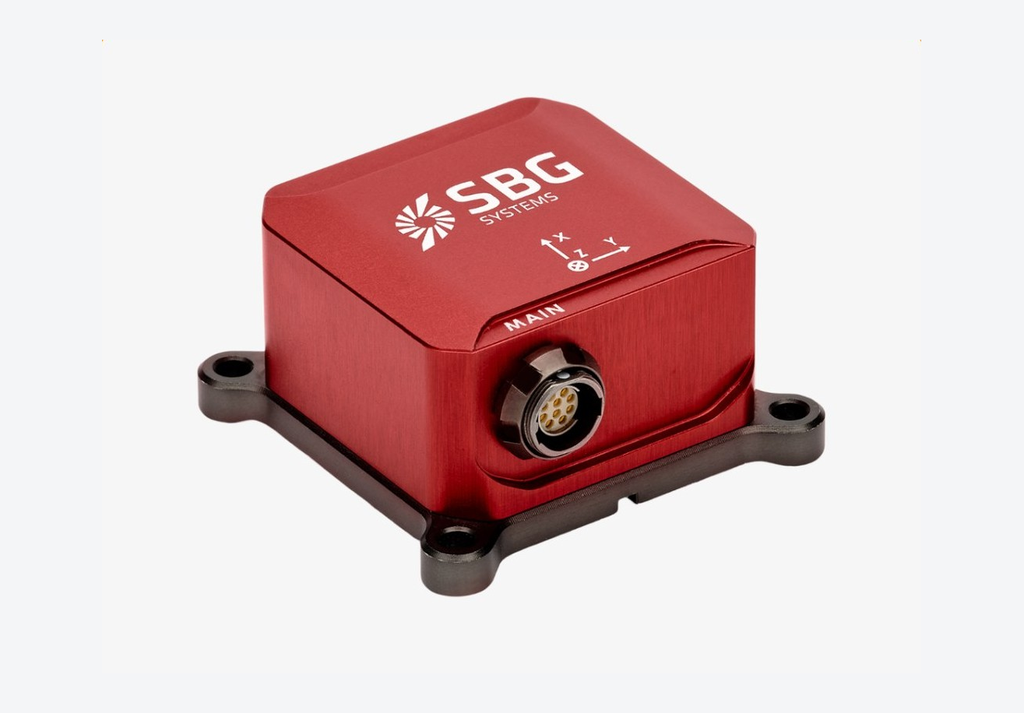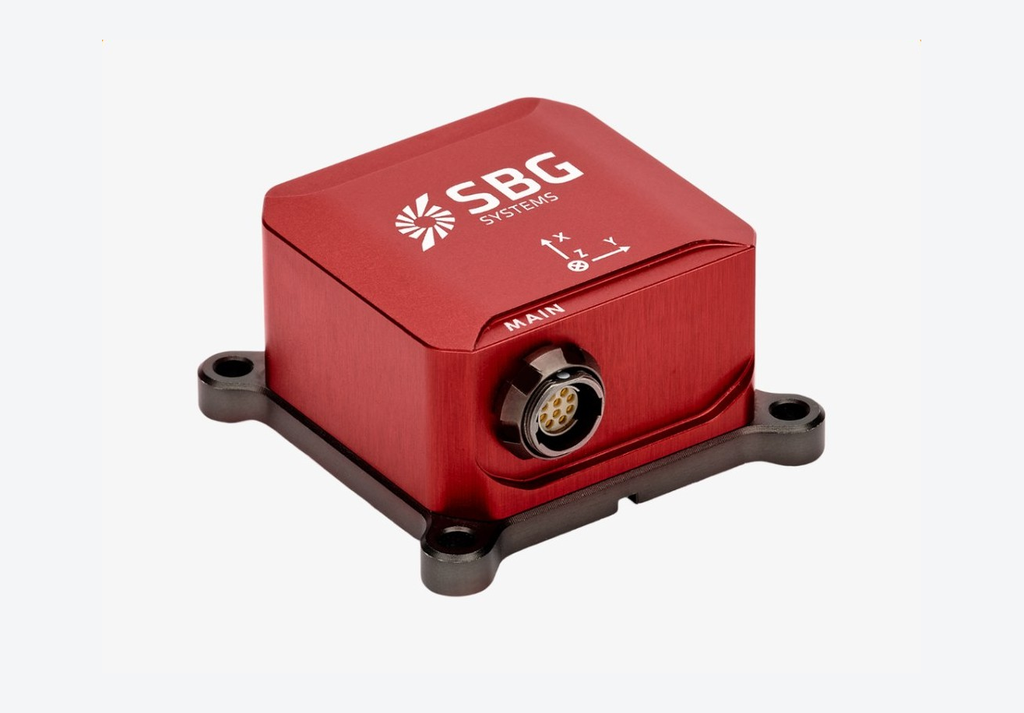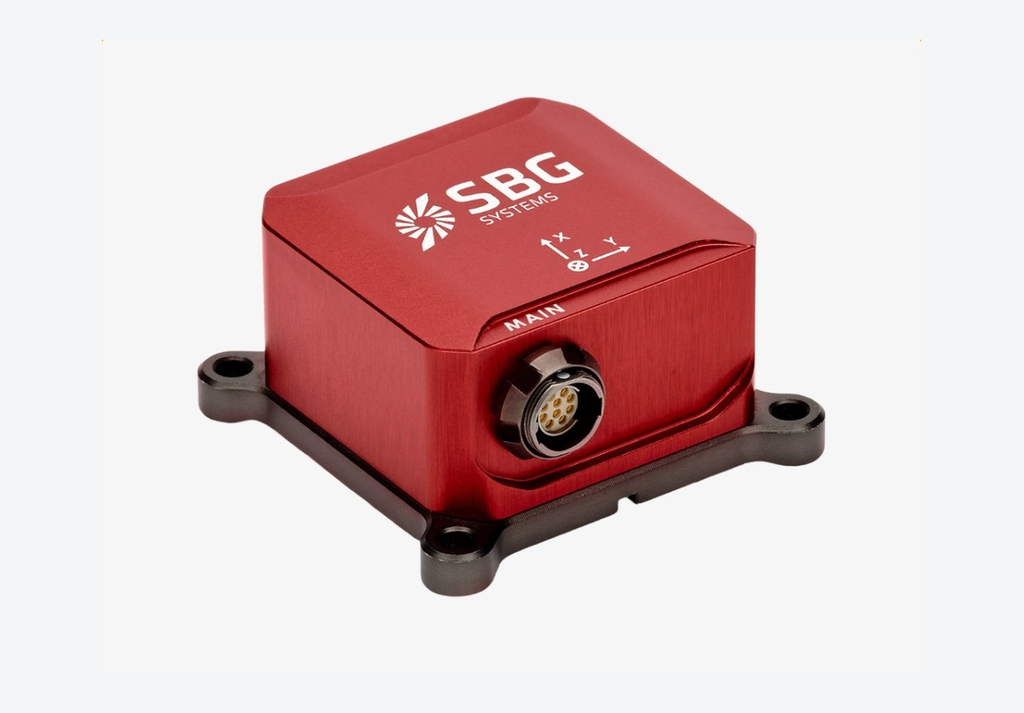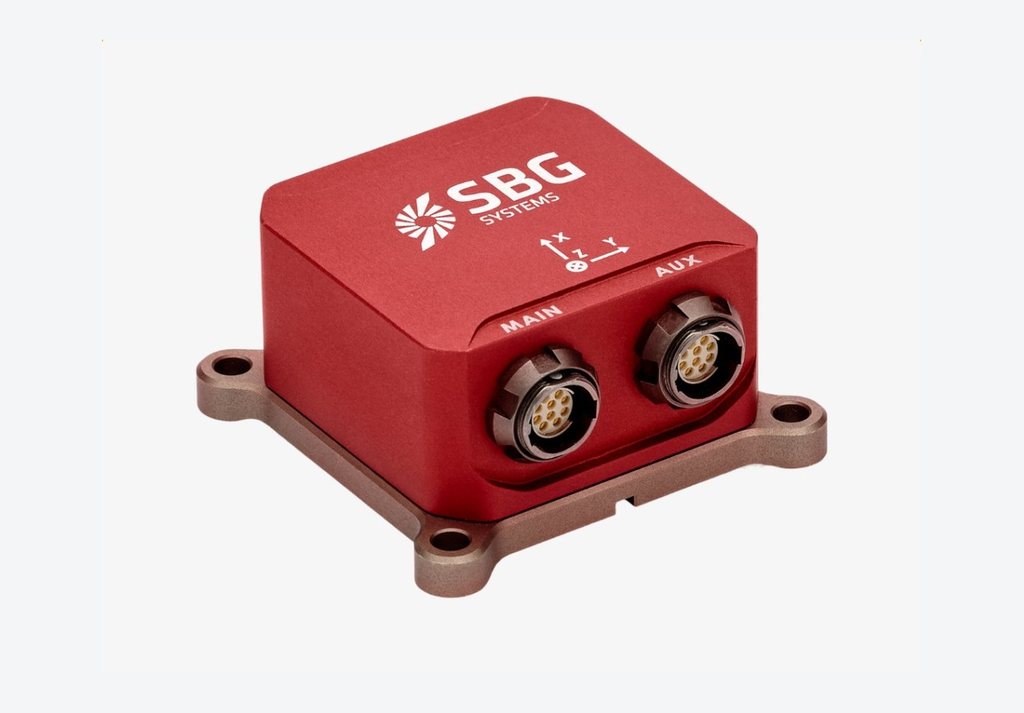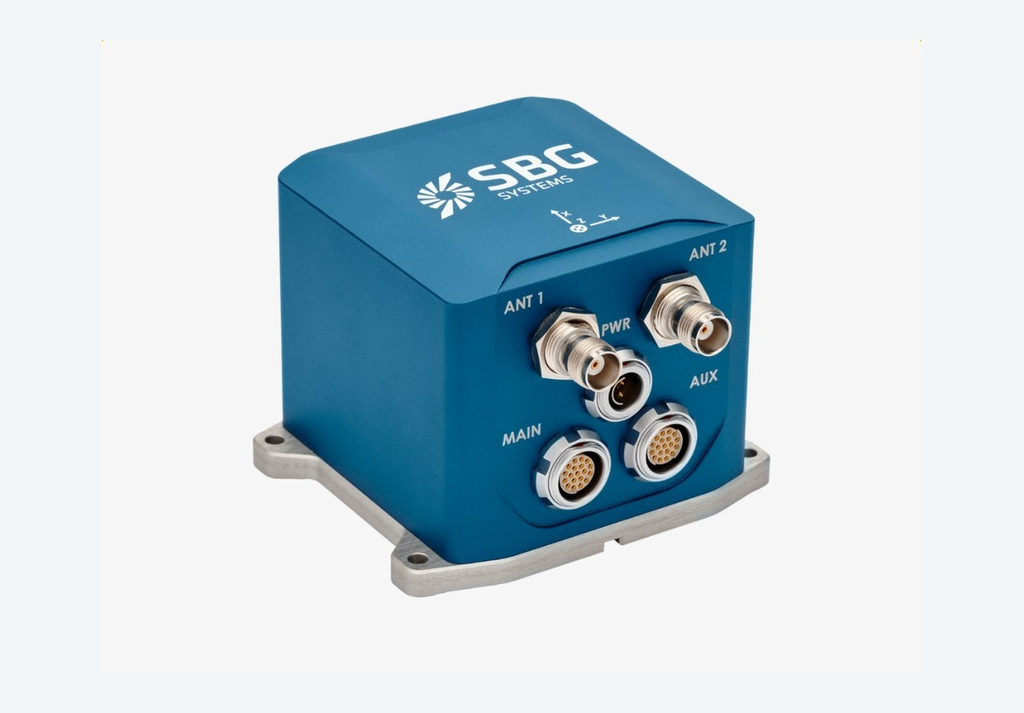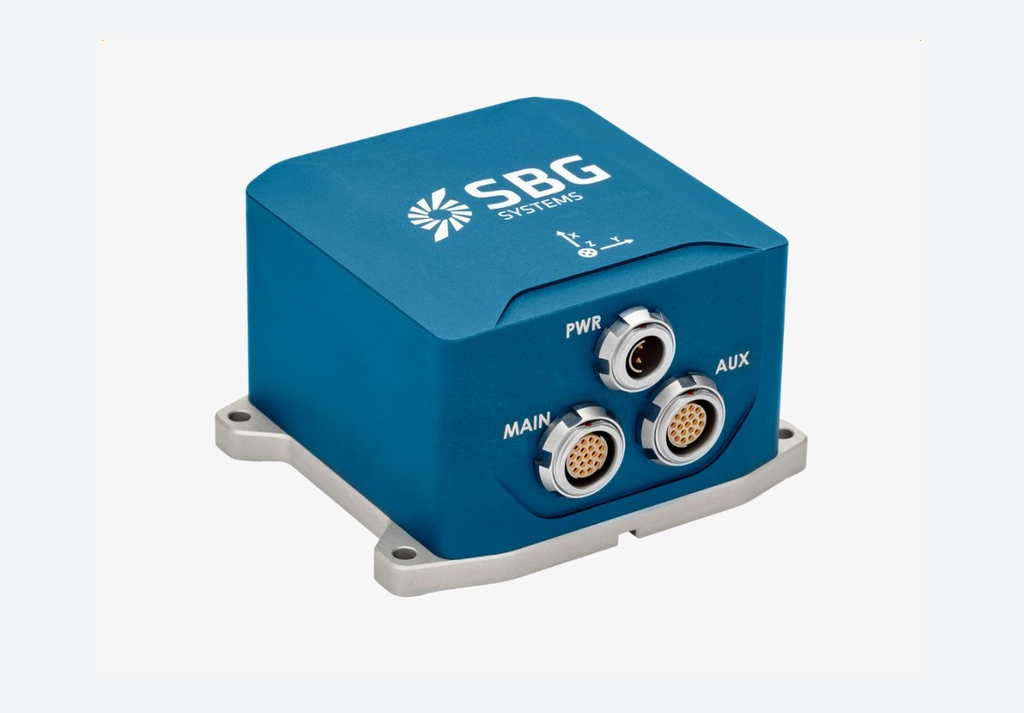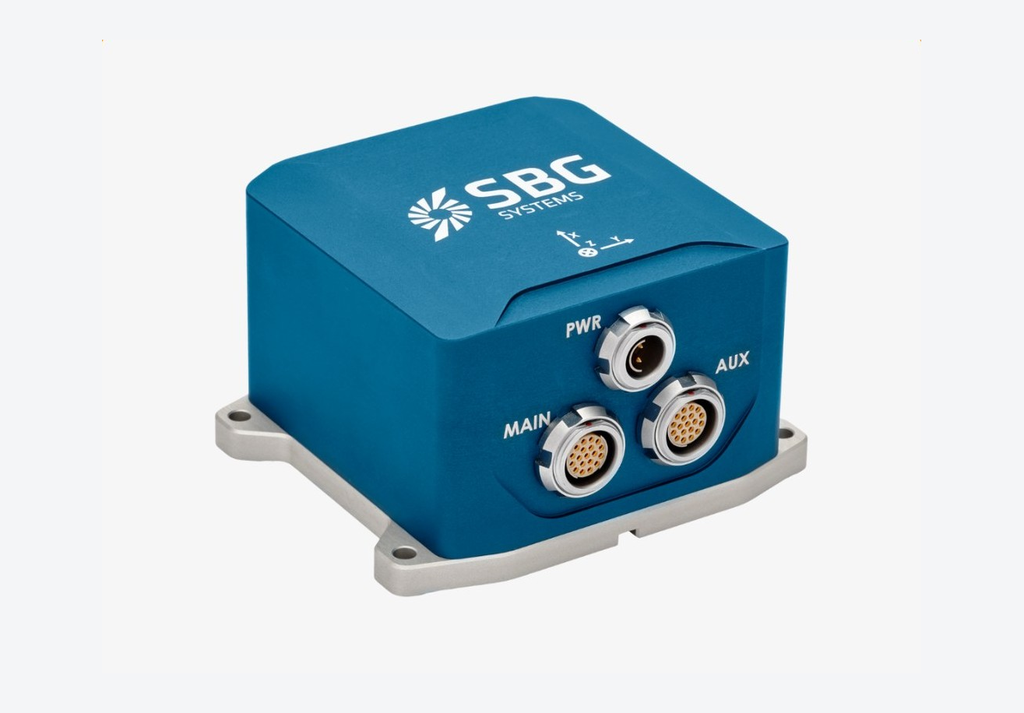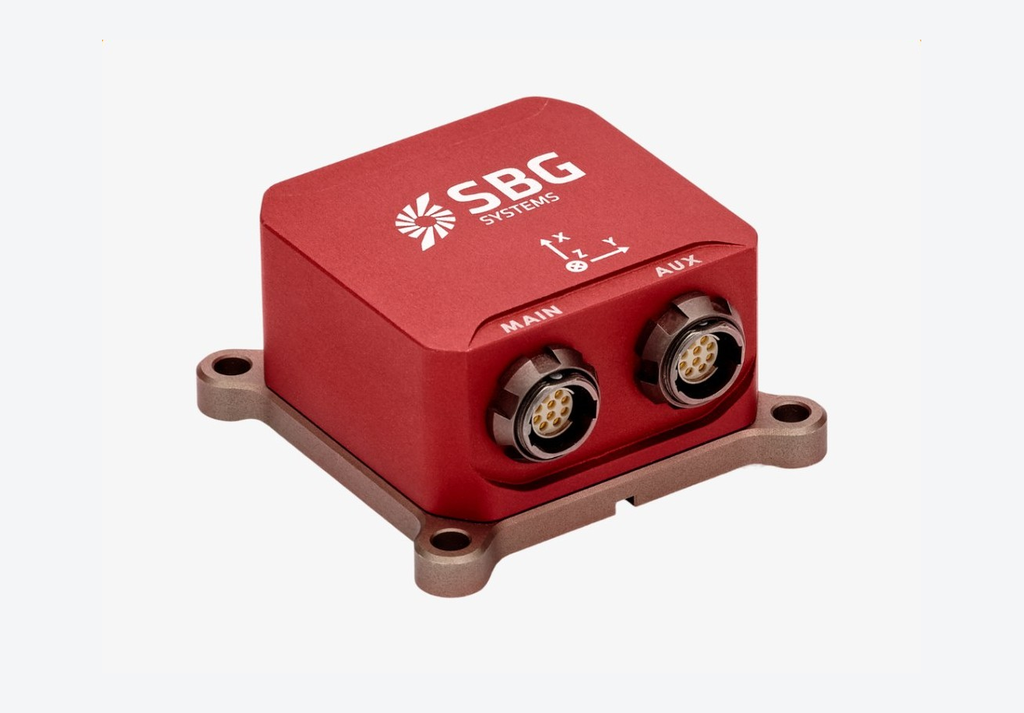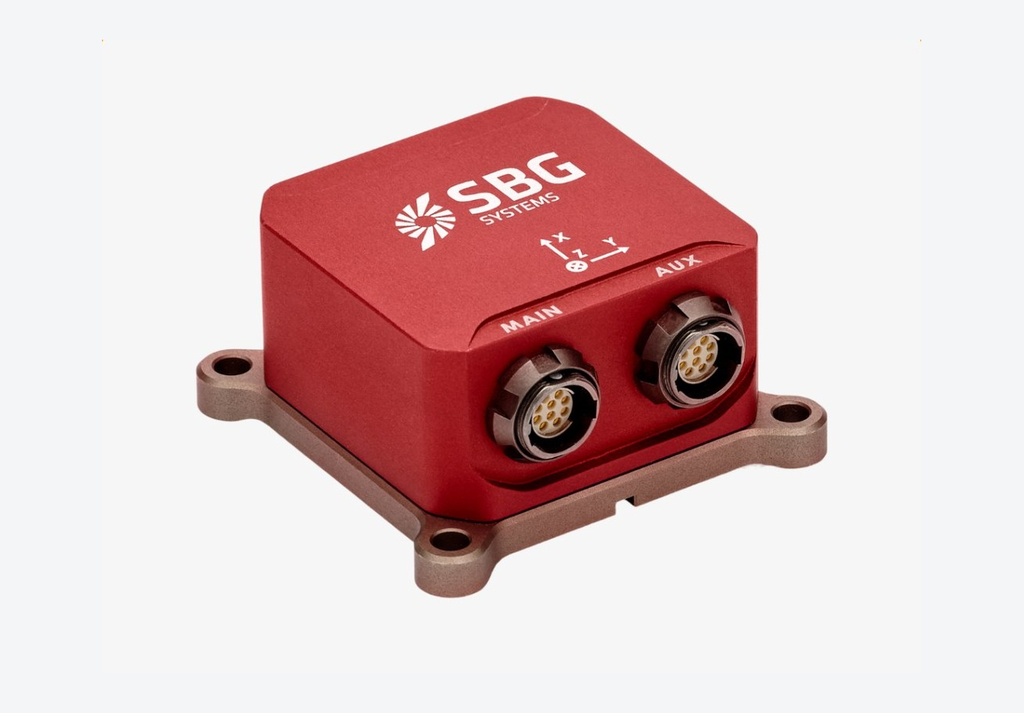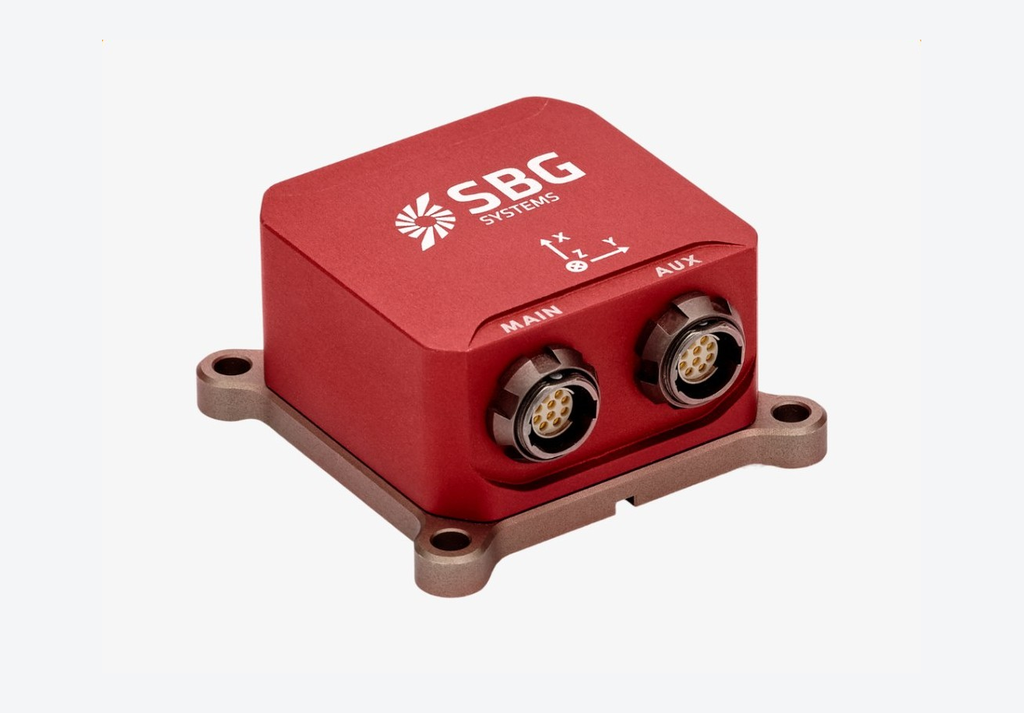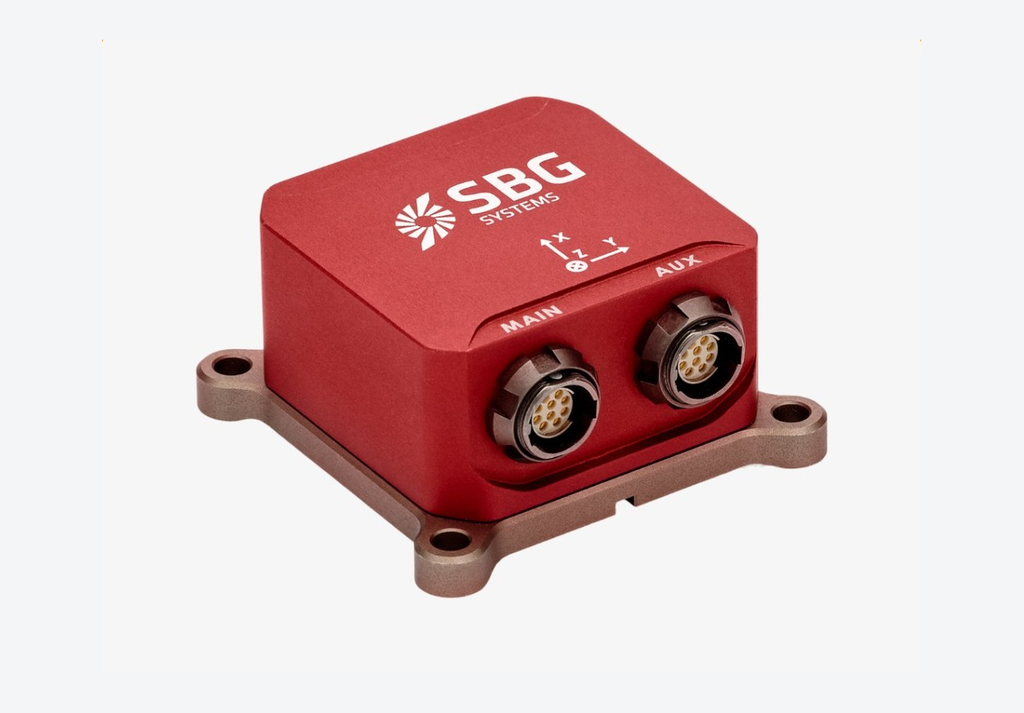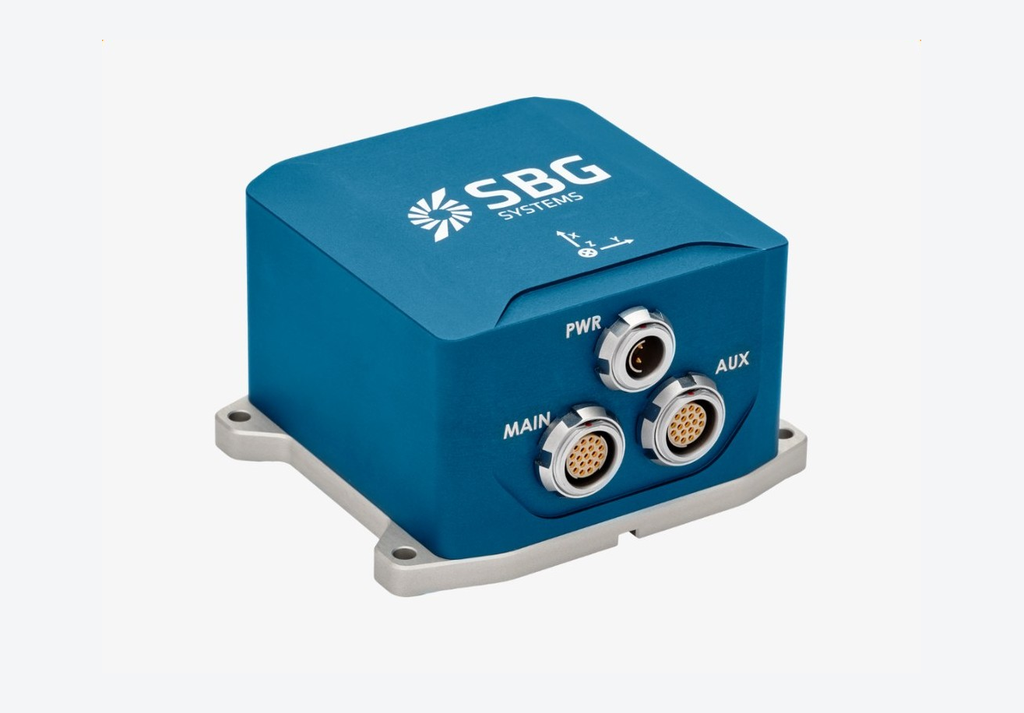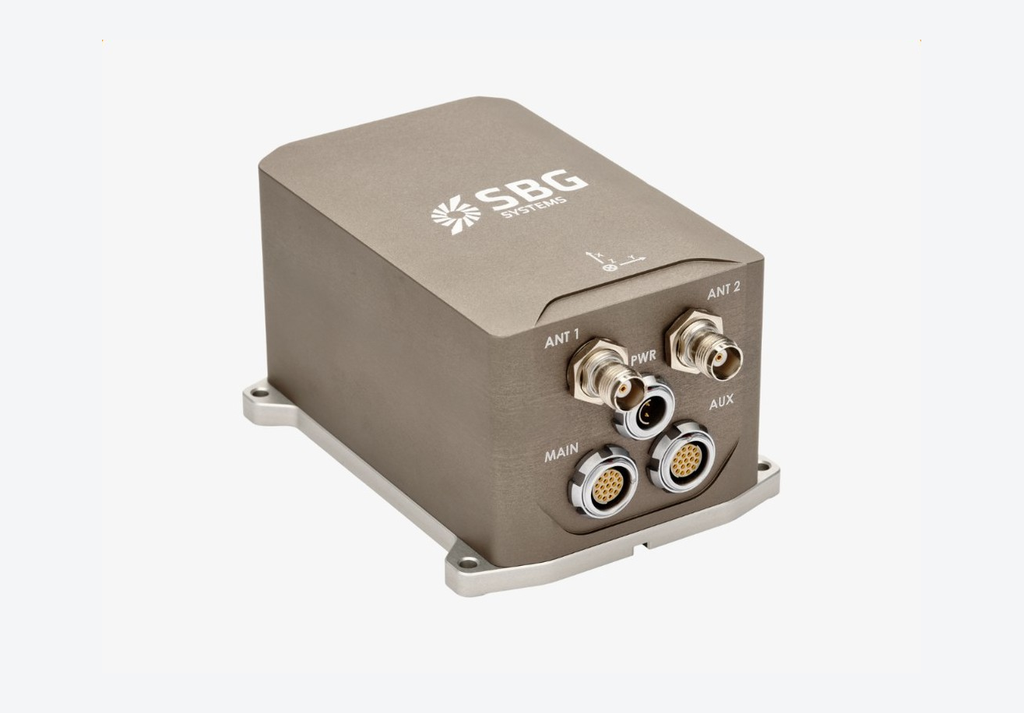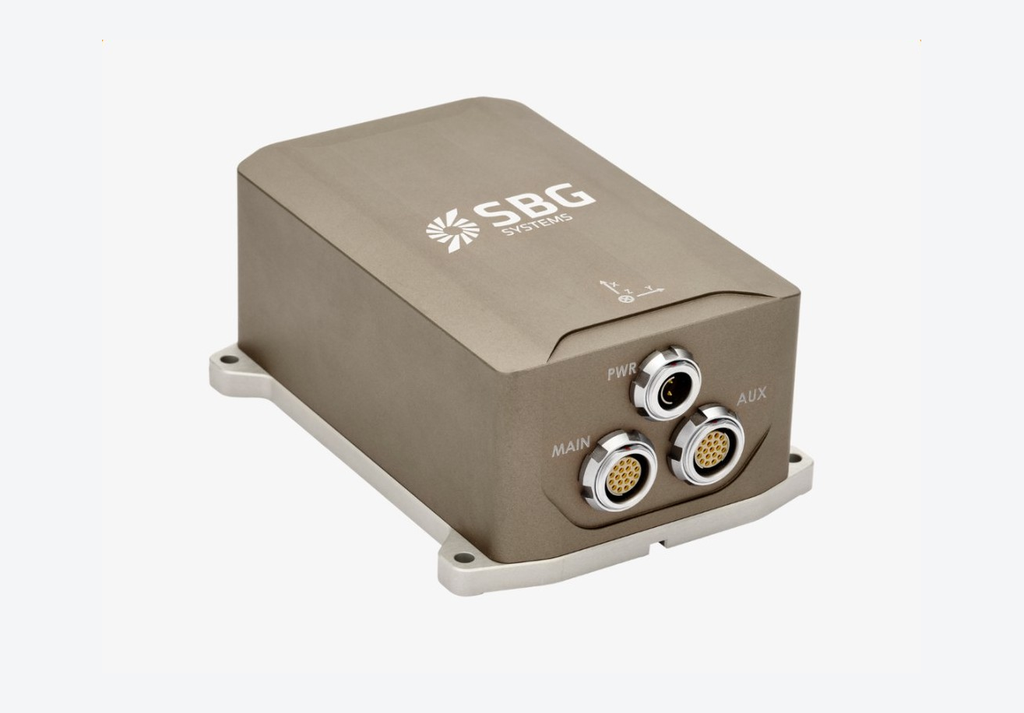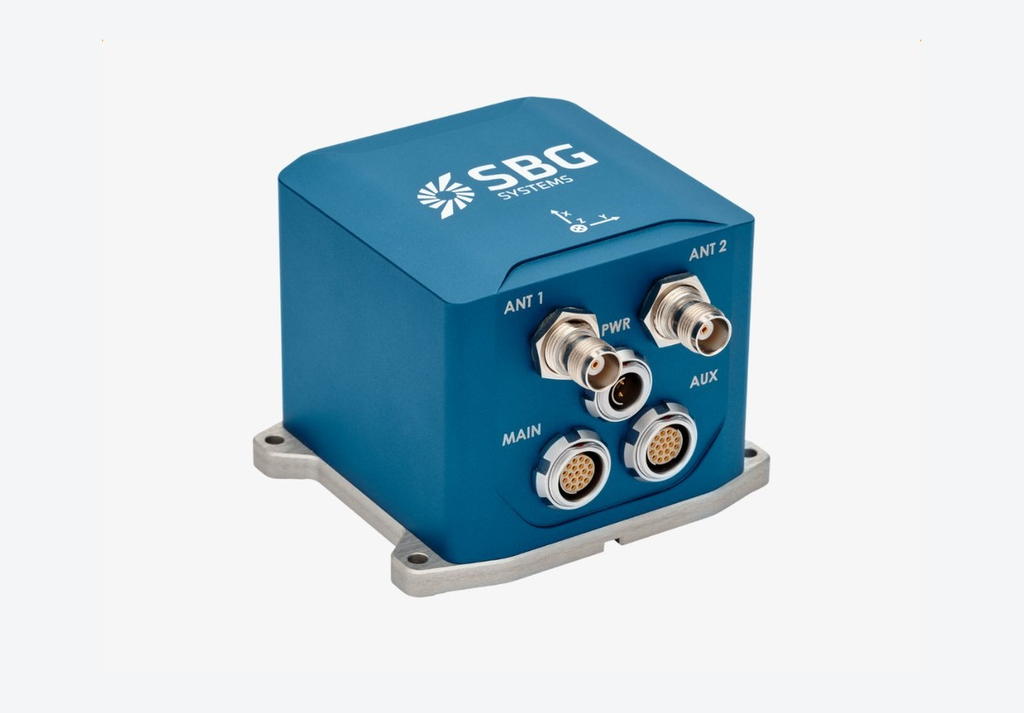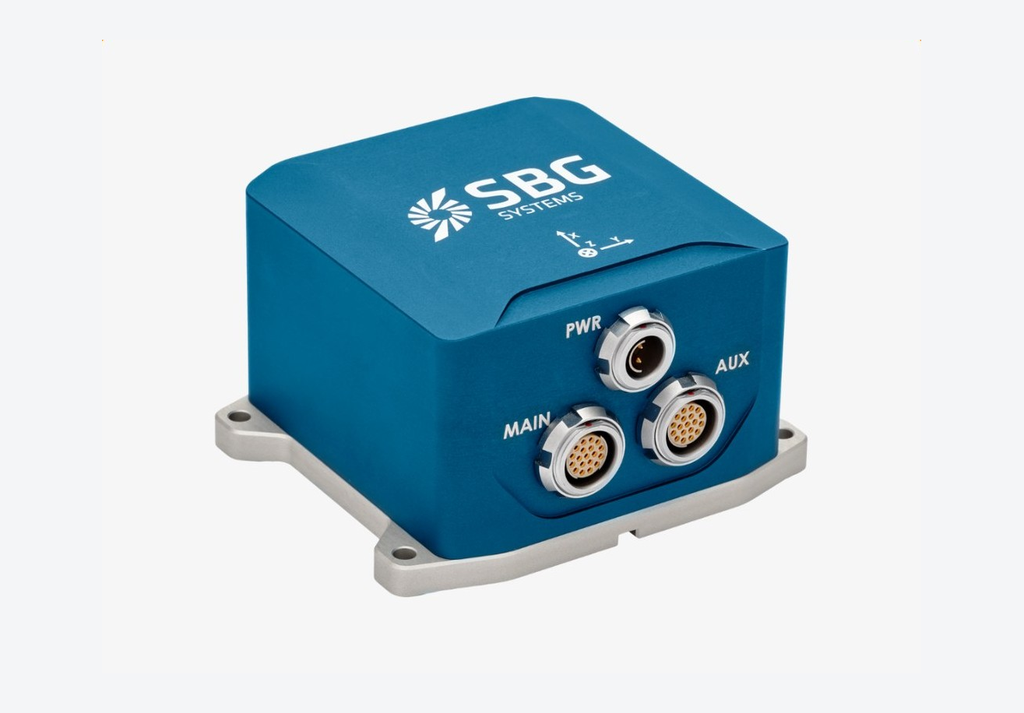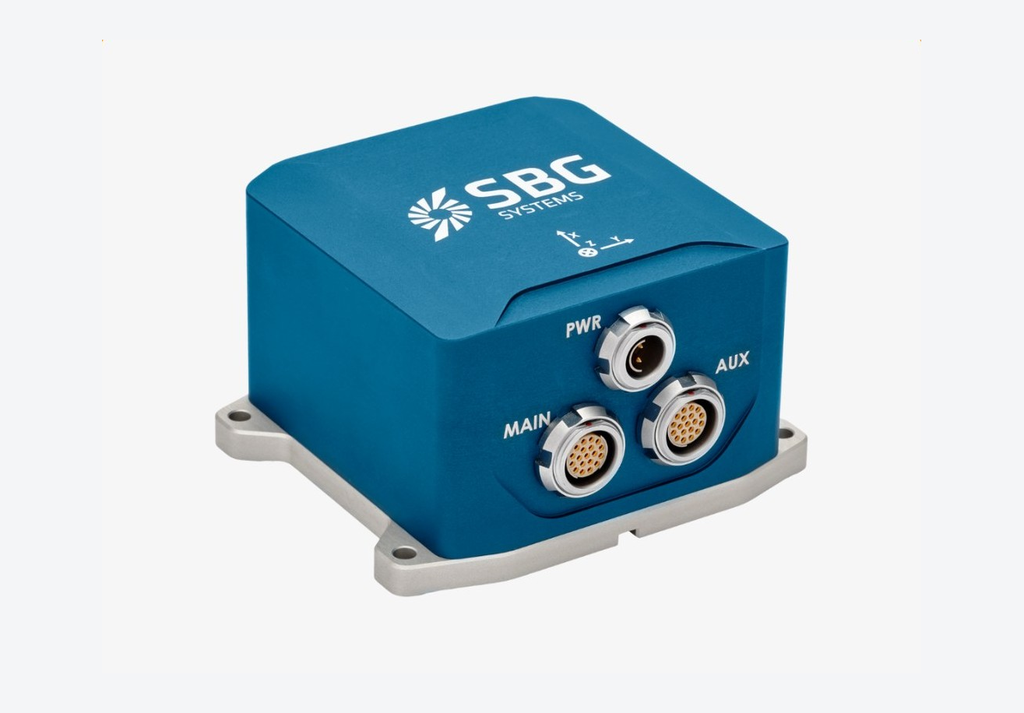
Ekinox Micro
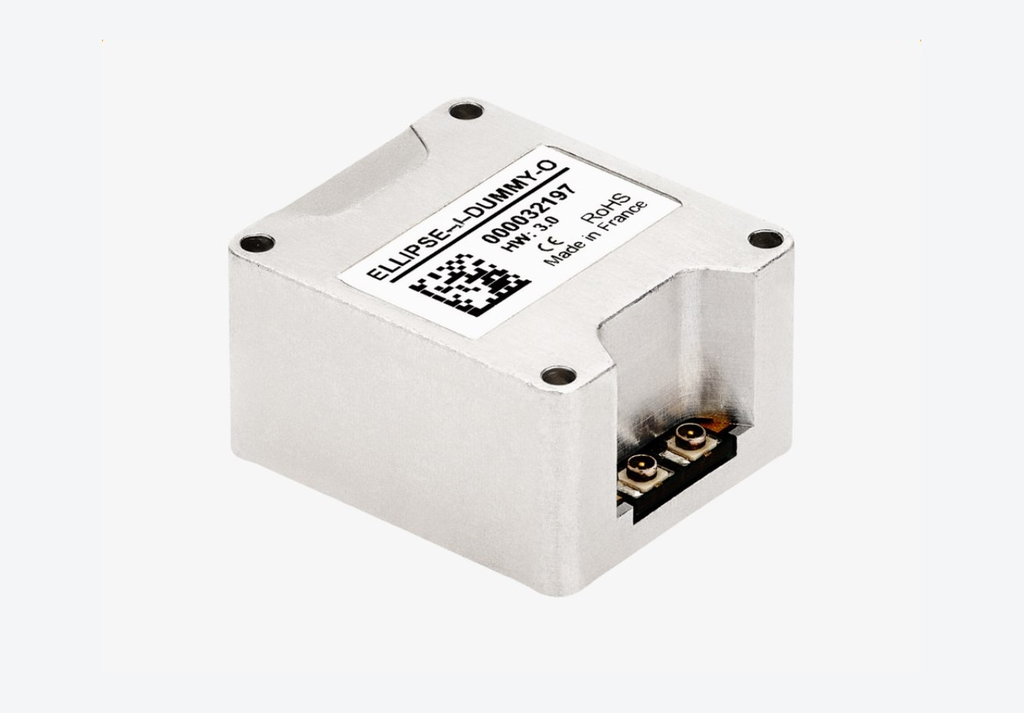
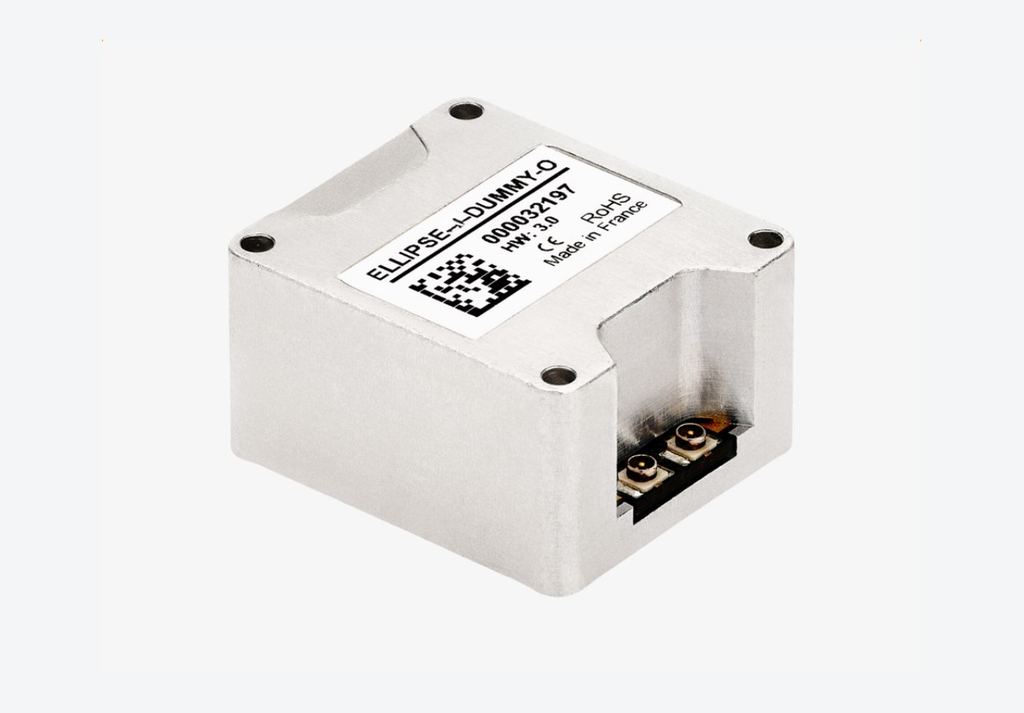
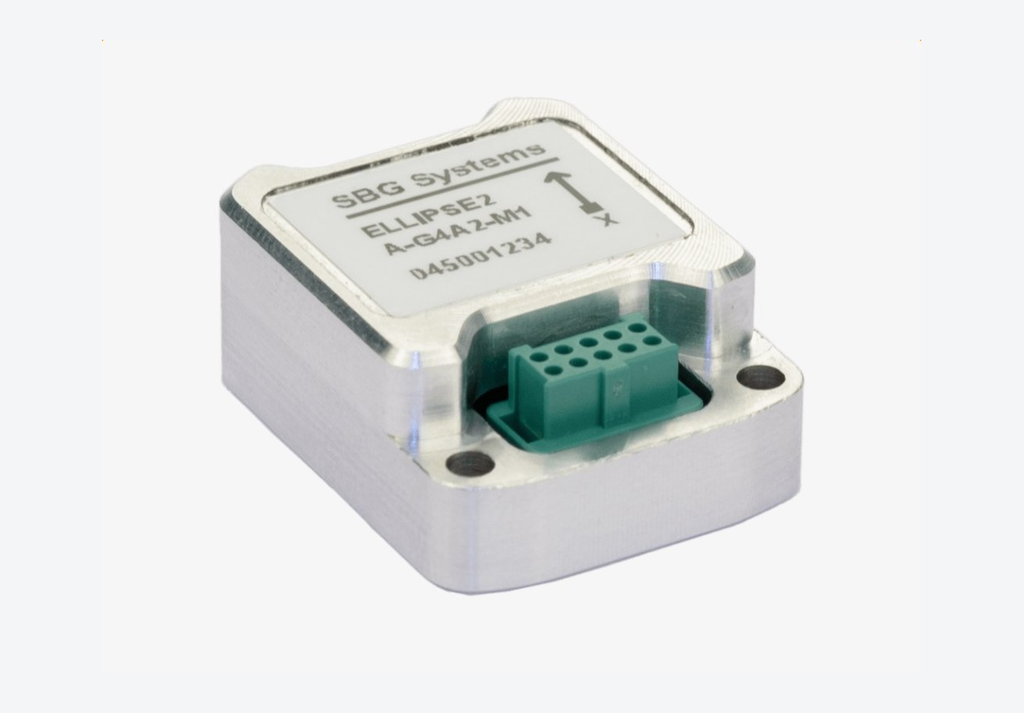
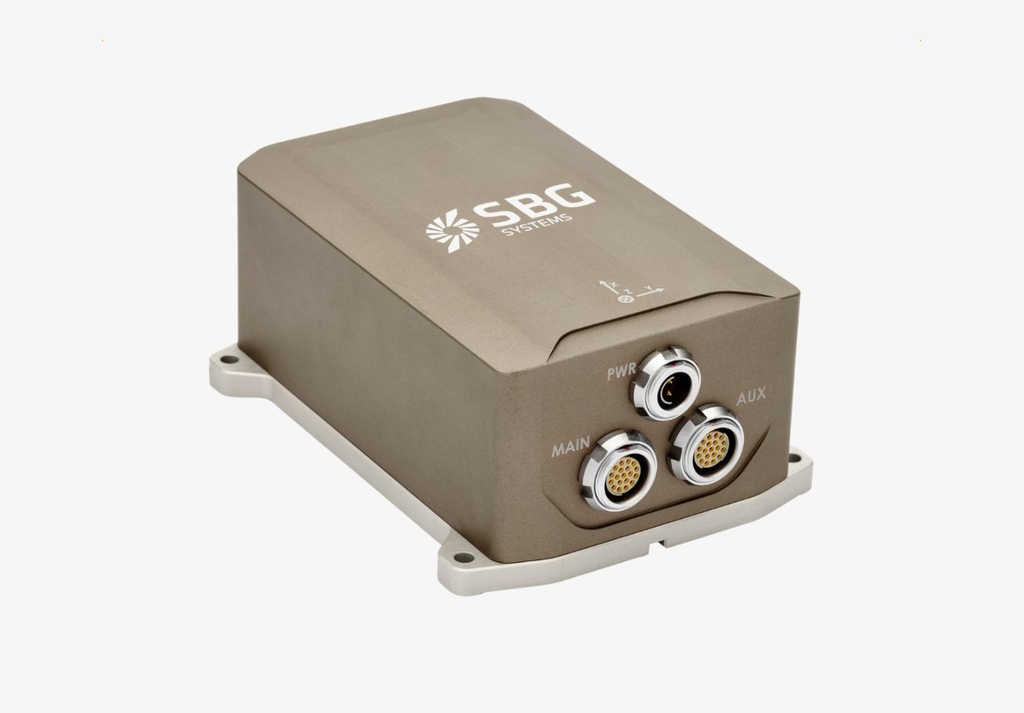
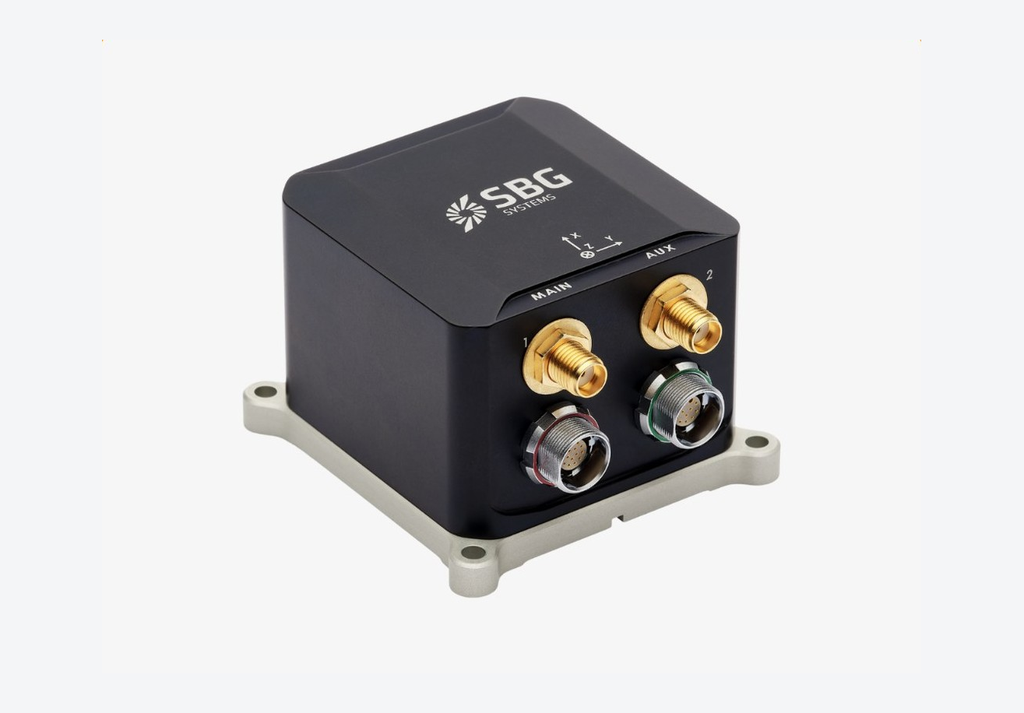
Ekinox Micro is a high-performance GNSS aided Inertial Navigation System (INS) designed for use in a variety of land, marine, and airborne applications.
490°/s, 40g
P/N: 100-2943
Ekinox Micro is a high-performance GNSS aided Inertial Navigation System (INS) designed for use in a variety of land, marine, and airborne applications.
Tactical-grade MEMS IMU in a housing: 0.1°/h gyro and 6 µg accelerometer bias instability, up to 2 kHz output, RS422 and 5–36 V input.
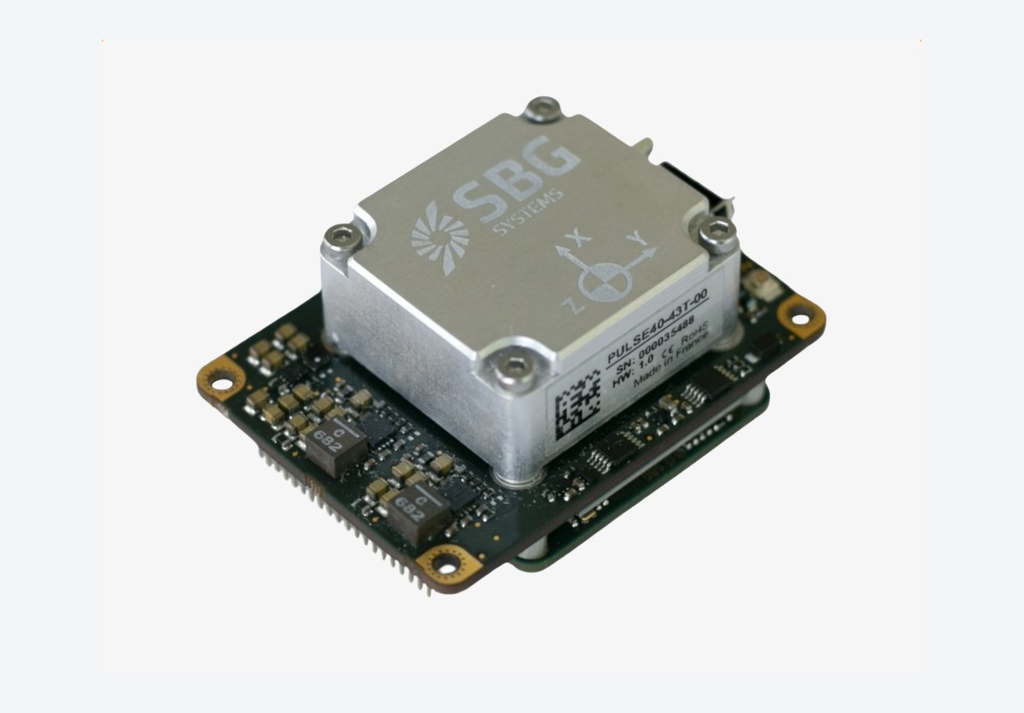
Miniature tactical-grade MEMS IMU (OEM): 0.8°/h gyro bias instability, 0.08°/√h ARW, ±490°/s range and 480 Hz bandwidth.
Miniature dual-antenna RTK INS: 0.05° roll/pitch with RTK, 0.2° heading and 1 cm RTK position; land and air version.
Serial interface board for the SBG Pulse-40 tactical-grade MEMS IMU (0.8°/h gyro bias instability), for connecting it to a host over a serial link.
Miniature single-antenna RTK INS: 0.05° roll/pitch with RTK, 0.2° heading with vehicle dynamics and 1 cm RTK position; CAN version.
Miniature single-antenna RTK INS: 0.05° roll/pitch with RTK, 0.2° heading with vehicle dynamics and 1 cm RTK position; land and air version.
Miniature dual-antenna RTK INS: 0.05° roll/pitch with RTK, 0.2° heading and 1 cm RTK position; CAN version for land and air.
Miniature dual-antenna RTK INS: 0.05° roll/pitch with RTK, 0.2° heading and 1 cm RTK position; marine version with heave output.
Tactical-grade GNSS/INS with a jamming- and spoofing-resilient receiver: 0.03° roll/pitch, 0.08° heading and 1 cm RTK; suspended mounting version.
Miniature 45 g AHRS with 0.1° roll/pitch, 0.8° magnetic heading and 200 Hz output, CAN version for land and air platforms.
Miniature marine AHRS with 0.1° roll/pitch, 0.8° heading and 5 cm heave in a 45 g package, for boats, buoys and marine sensors.
Miniature 45 g AHRS with 0.1° roll/pitch, 0.8° magnetic heading and 200 Hz output over RS-232, RS-422 or USB, for land and air platforms.
Miniature INS for an external GNSS receiver with built-in barometer: 0.1° roll/pitch, 0.2° heading, 0.03 m/s velocity; marine CAN version.
Compact GNSS-aided INS for UAV mapping: 0.03° roll/pitch, 0.1° heading (0.06° dual antenna) and multi-frequency quad-constellation GNSS with RTK and PPK.
All-in-one INS with integrated RTK GNSS receiver: 0.02° roll/pitch, 0.03° heading and 1 cm RTK position, with Marinestar support, for land and air.
Marine INS and MRU for an external GNSS receiver: 0.02° roll/pitch, 0.03° heading and heave output at 200 Hz, for vessels and hydrography.
Marine MRU with 0.02° roll/pitch, 5 cm real-time heave and 200 Hz output, for vessel motion compensation and hydrographic survey.
High-performance MEMS AHRS: 0.02° roll/pitch, 0.03° heading, 200 Hz output and 8 GB data logging, for land and air platforms.
Tactical-grade MEMS IMU as an OEM board: 0.1°/h gyro and 6 µg accelerometer bias instability, up to 2 kHz, UART, 5–12 V and under 1.3 W.
Sub-miniature MEMS AHRS: 0.1° roll/pitch, 0.8° heading, 7°/h gyro bias instability and ±450°/s range, for small platforms.
Miniature INS for an external GNSS receiver with built-in barometer: 0.1° roll/pitch, 0.2° heading, 0.03 m/s velocity; land and air version.
Miniature INS for an external GNSS receiver with built-in barometer: 0.1° roll/pitch, 0.2° heading, 0.03 m/s velocity; CAN version for land and air.
Miniature INS for an external GNSS receiver with built-in barometer: 0.1° roll/pitch, 0.2° heading, 0.03 m/s velocity; high-dynamics version.
Miniature INS for an external GNSS receiver with built-in barometer: 0.1° roll/pitch, 0.2° heading, 0.03 m/s velocity; high-dynamics CAN version.
Miniature INS for an external GNSS receiver with built-in barometer: 0.1° roll/pitch, 0.2° heading, 0.03 m/s velocity; marine version with heave.
INS for an external GNSS receiver: 0.02° roll/pitch, 0.03° heading, 200 Hz output, 400 g and 3 W; land and air version.
Tactical-grade GNSS/INS with a jamming- and spoofing-resilient receiver: 0.03° roll/pitch, 0.08° heading and 1 cm RTK; rigid mounting version.
Compact INS/GNSS with the Pulse-80 IMU: 0.008° roll/pitch, 0.02° heading, 1 cm RTK and triple-frequency quad-constellation GNSS with anti-jamming.
Dual-antenna INS/GNSS: 0.01° roll/pitch and 0.02° heading at 2 m baseline, 30 µg bias instability, compact and cost-effective for survey and mapping.
INS for an external GNSS receiver: 0.01° roll/pitch, 0.02° heading with a dual-antenna receiver, 200 Hz and 3 W, for survey, hydrography and mapping.
Dual-antenna RTK INS: 0.02° roll/pitch, 0.03° heading and 1 cm + 0.5 ppm RTK position in a 400 g unit, for survey, mapping and autonomous vehicles.
INS with external GNSS input: 0.02° roll/pitch, 0.03° heading and centimetre position with an RTK receiver, 400 g and 3 W.
Board-level dual-antenna RTK INS (SMD): 0.05° roll/pitch with RTK, 0.2° heading and 1 cm RTK position, for integration into UAVs and robots.
Board-level single-antenna RTK INS (SMD): 0.05° roll/pitch with RTK, 0.2° heading with dynamics and 1 cm RTK position, for UAVs and robots.
Board-level INS for an external GNSS receiver: 0.1° roll/pitch, 0.2° heading and 0.03 m/s velocity with a built-in barometer, for OEM integration.
Sub-miniature MEMS IMU with 7°/h gyro and 14 µg accelerometer bias instability, 0.15°/√h ARW, ±450°/s and ±16 g ranges.
AHRS and MRU with 0.01° roll/pitch, 0.02° heading, 5 cm real-time heave and under 7 µg accelerometer bias, for motion compensation and survey.
MEMS AHRS and MRU with 0.02° roll/pitch, 0.03° heading, 5 cm heave and under 10 µg accelerometer bias, for motion compensation and stabilisation.
8 g board-level AHRS with 0.1° roll/pitch, 0.8° magnetic heading and 200 Hz output, for integration into UAVs, robots and handheld devices.
Sub-miniature AHRS for dynamic orientation: 0.1° roll/pitch and 0.8° heading, 7°/h gyro bias instability, ±16 g accelerometers, for UAVs and robots.
High-Precision MEMS Gyroscope with Industry-Leading Bias Stability
High-Performance MEMS Gyroscope with Ultra-Low Noise for Precision Sensing
Tactical-Grade Closed-Loop Accelerometer with 2.5 µg Bias Instability
Miniature Single-Axis Gyroscope with 1°/hr Bias Instability
Silicon Sensing CMS390 (Orthogonal) MEMS Combi-Sensor combines a single-axis gyroscope and a dual-axis accelerometer for precise inertial measurements.
Silicon Sensing CMS300 (In-Plane) MEMS Combi-Sensor integrates a high-precision gyroscope and accelerometer into a compact package.
Six-axis MEMS IMU with 0.1°/h gyro bias instability, 0.02°/√h angle random walk and ±490°/s range, for navigation and stabilisation.
High-Precision MEMS Gyroscope Available in Housed and OEM Versions
Low Noise and Excellent Bias Stability for Accurate Measurements